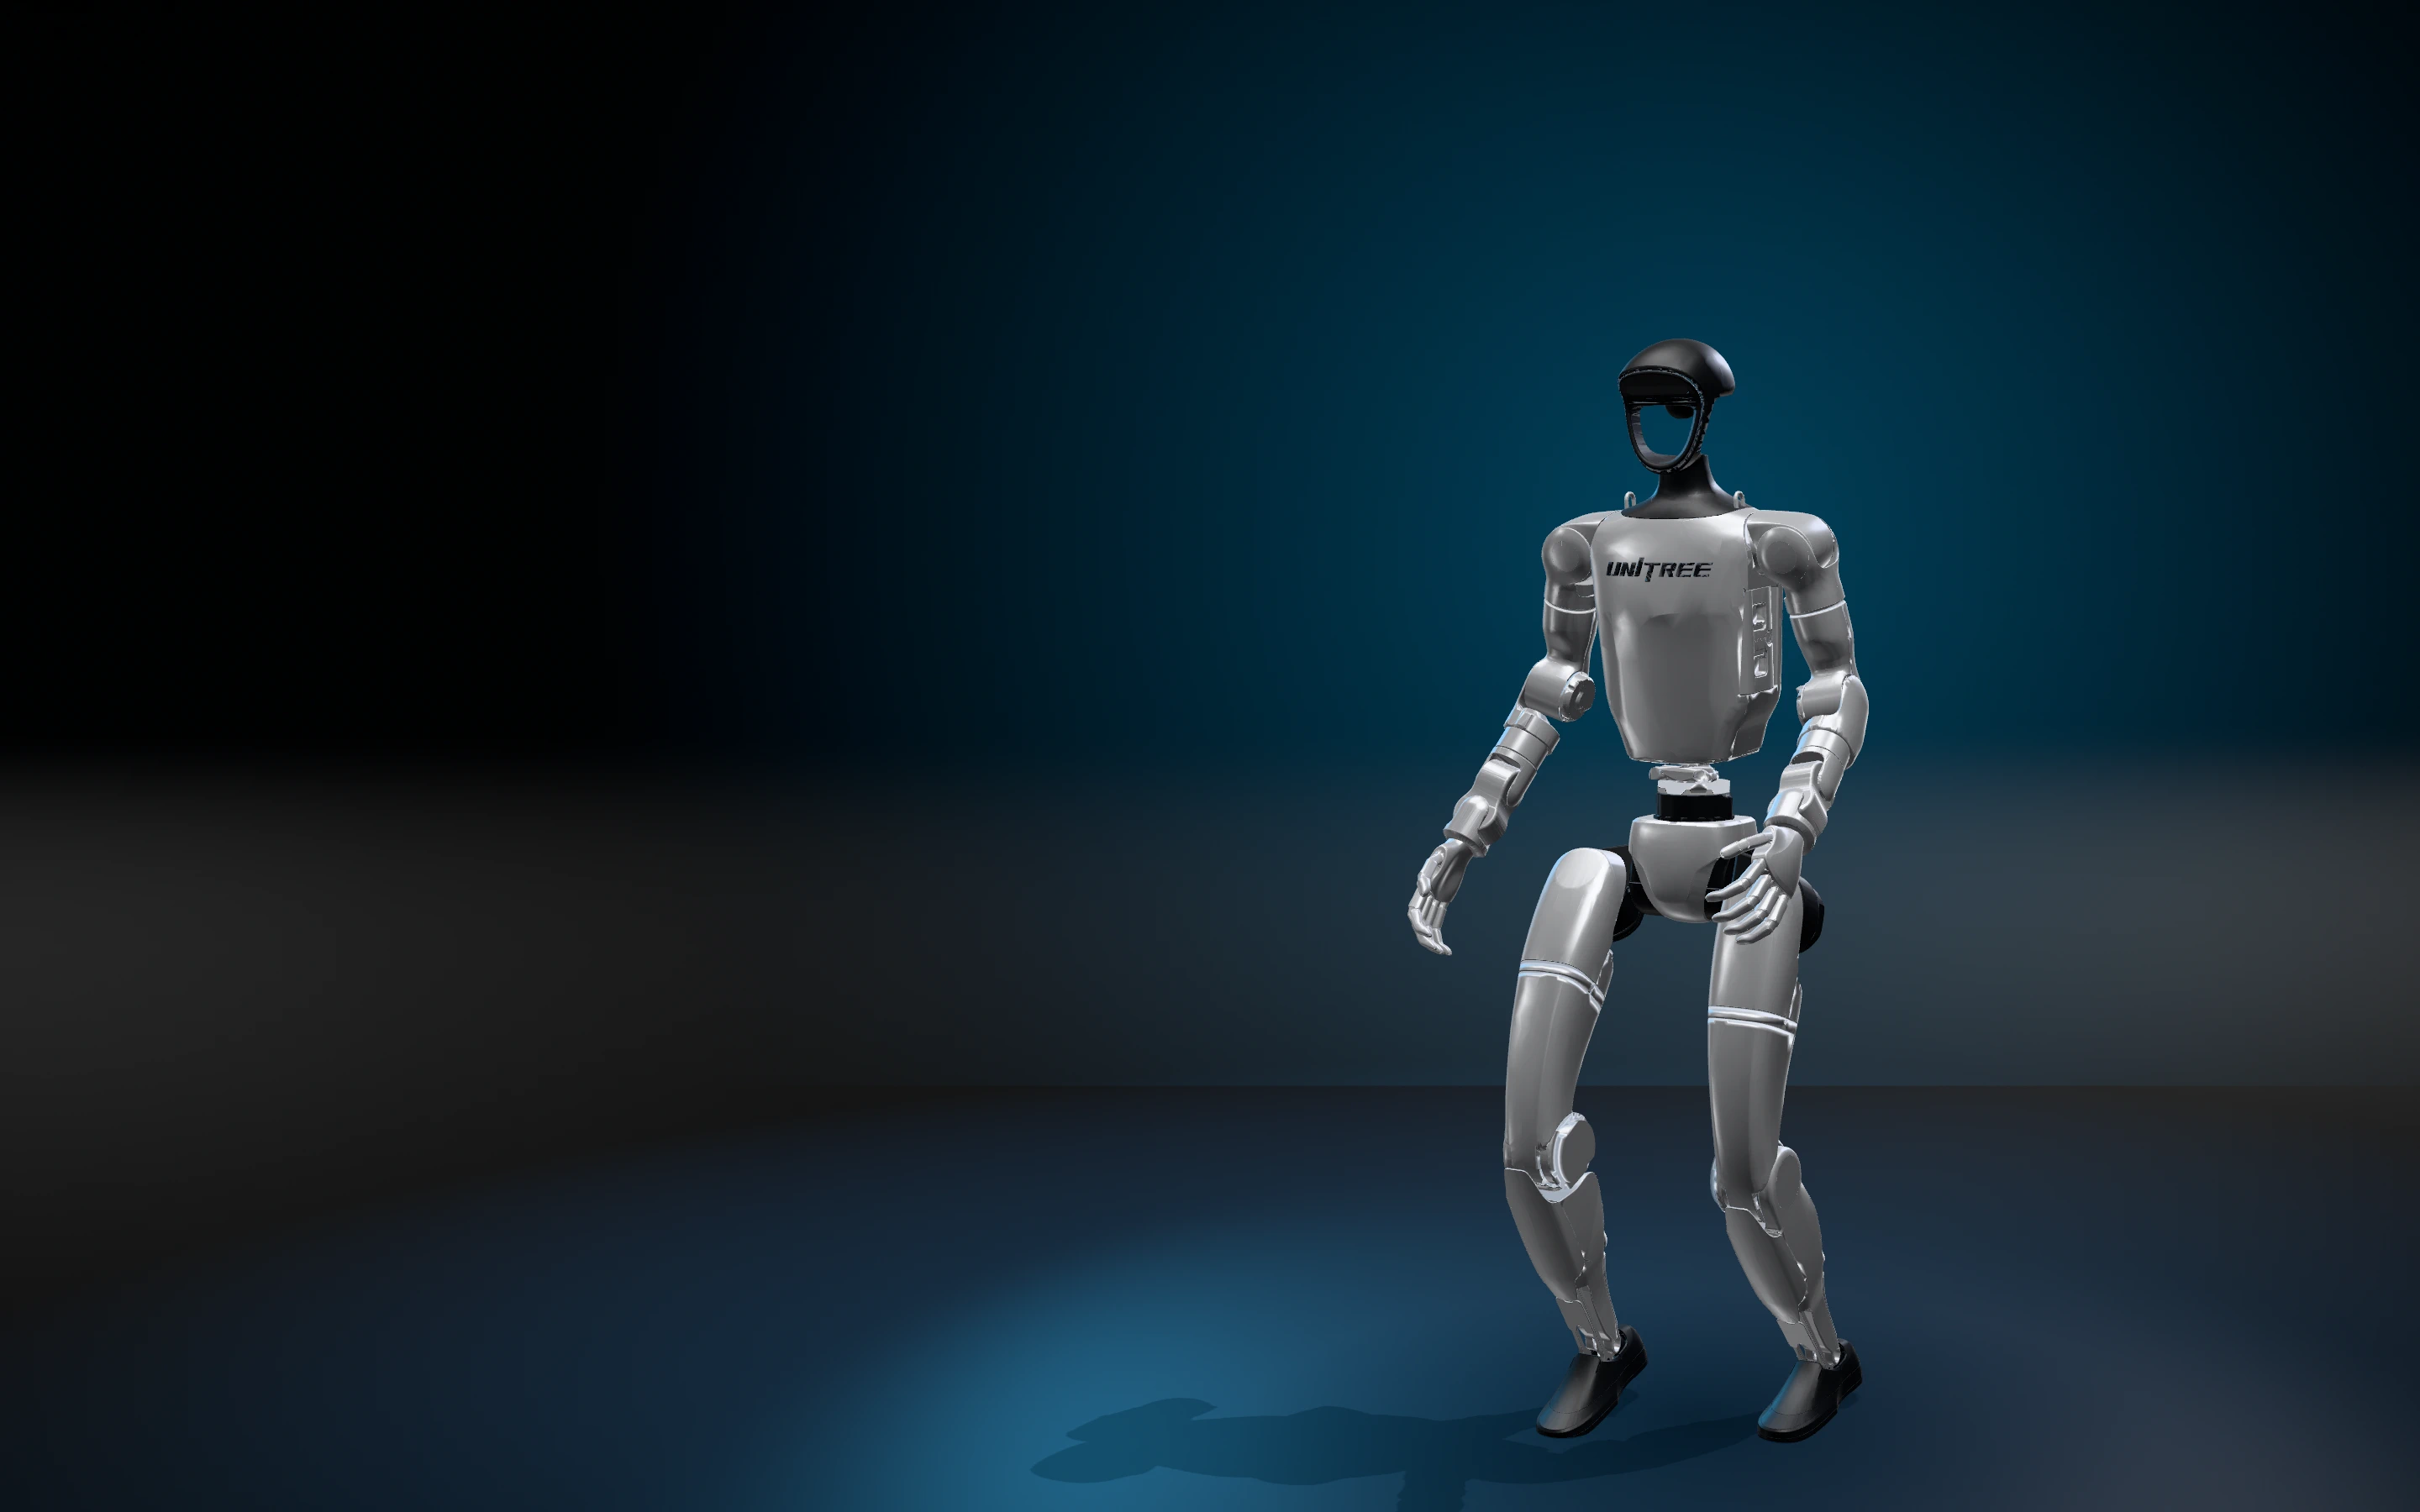
Zero hours of experience.
Generation 0 has never trained. Every motor holds the same bent-knee pose, and gravity does the rest.
0trained generations so far
A Unitree G1 trains in public on real physics. Every step it takes, and every fall, goes on the record.
Generation 0 has never trained. Every motor holds the same bent-knee pose, and gravity does the rest.
You are watching the published recording of that attempt, replayed on real physics in your browser. Each pale figure is an earlier moment of the same fall.
Each glowing point is a joint, and each joint is a seat. Burn $GAIT to hold one, then set how much torque it gets in the next generation.
See the jointsThe policy, three recordings and the metrics ship with a sha256 for each file. A contract on Robinhood Chain will keep every manifest hash for good.
f2d0a310e0dd9caea059…Read from the published feed every 30 seconds. Nothing on this panel is typed in by hand.
Reading the published feed.
Open the consoleFour steps run for every generation, and each one leaves something you can check.
PPO on a rented RTX 4090, with 8,192 copies of the robot stepping in parallel.
brax 0.14.2, 10M steps per generation
The exported policy runs 100 episodes in plain C MuJoCo on fixed seeds, away from the training code.
20 s episodes, 50 Hz, no noise
The policy, three recordings and the metrics go out as files, each with its sha256.
manifest.json, policy.onnx, rollout-*.bin
The manifest hash lands on Robinhood Chain, where nobody can edit it afterwards.
GaitLedger, chain 4663, at launch
Whoever has burned the most $GAIT into a joint holds it and sets its torque between 0.70 and 1.00. The next generation trains on that body, and its gait has to adapt.
Seats open when the token goes live on Robinhood Chain. The contract address goes out on X first.